Over 60,000 vessels call at European ports every year, and manual inspection can't keep pace. Biofouling of just 2.5mm increases emissions by up to 34%
From a real hull survey to a measurable 3D model
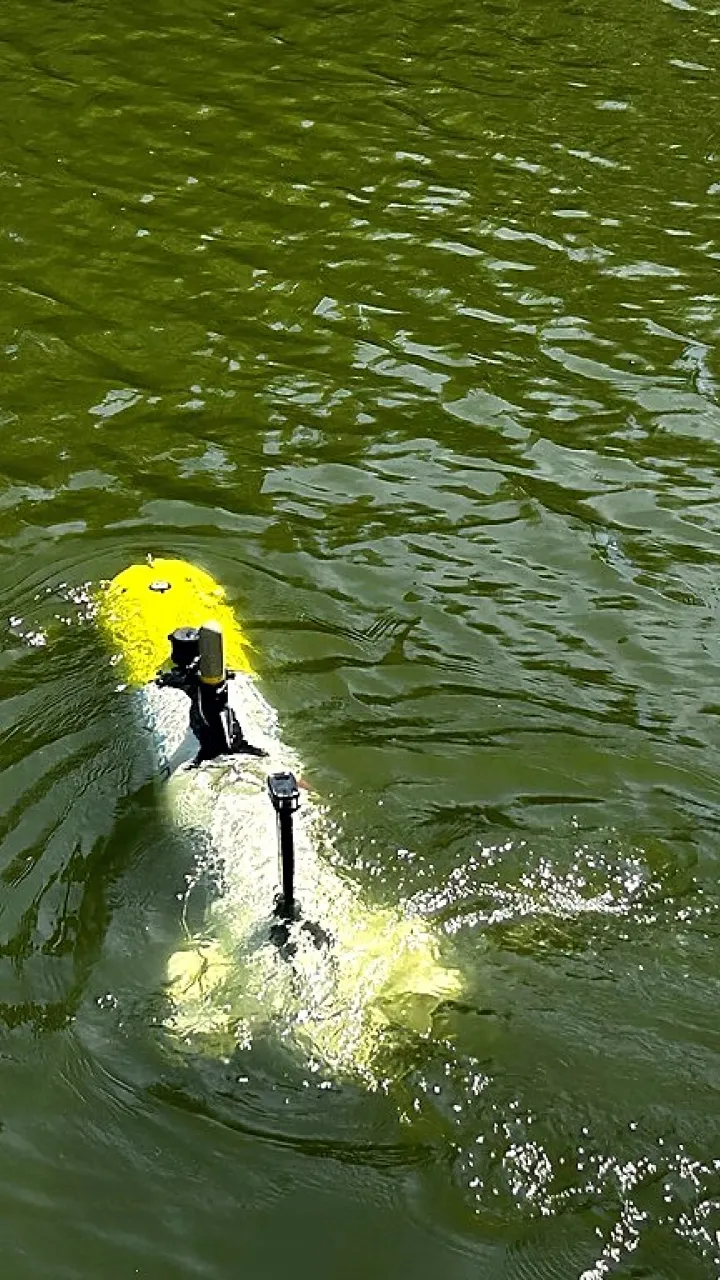
Real subdron AUV mission at berth. What the vehicle collects becomes a cm-accurate 3D hull reconstruction, built straight from raw acoustic data.
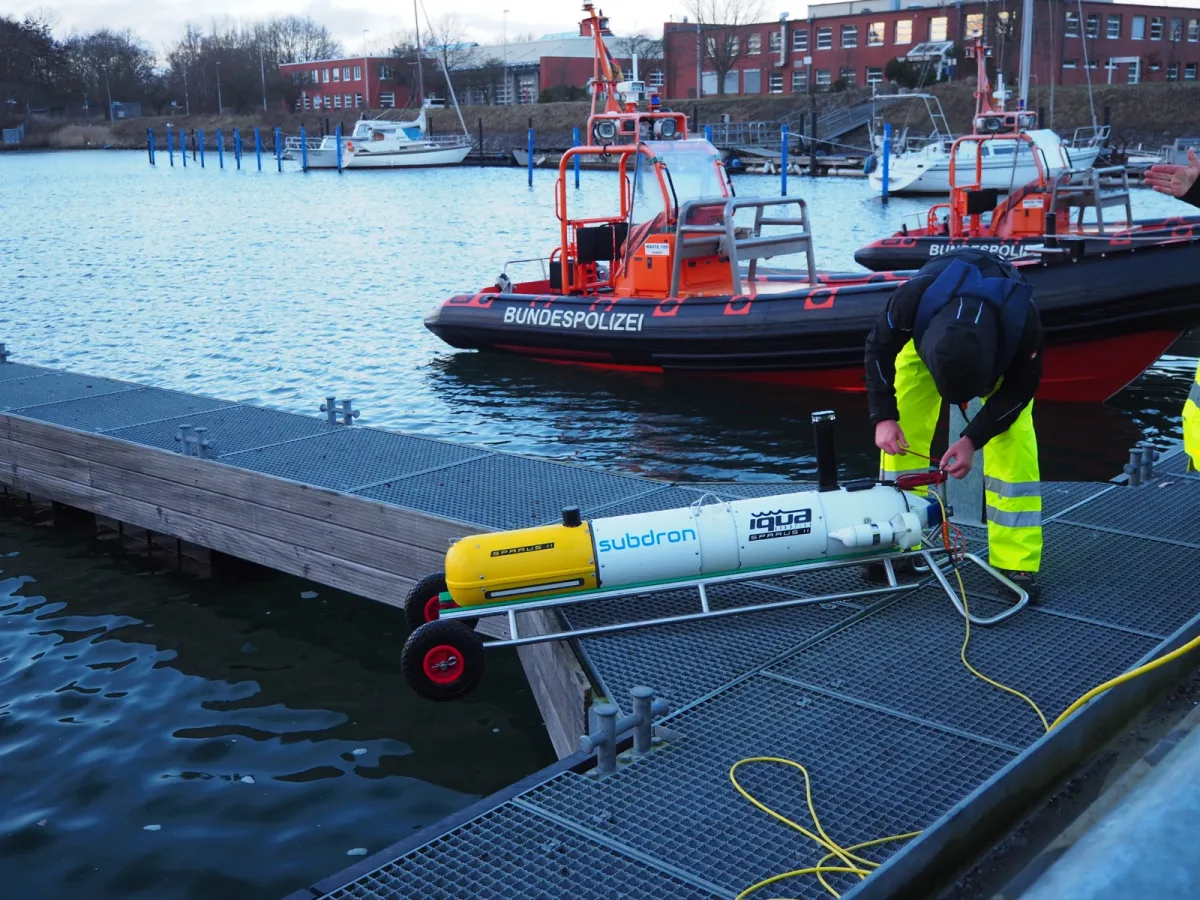
No drydock, no divers, complete hull coverage in a single mission.
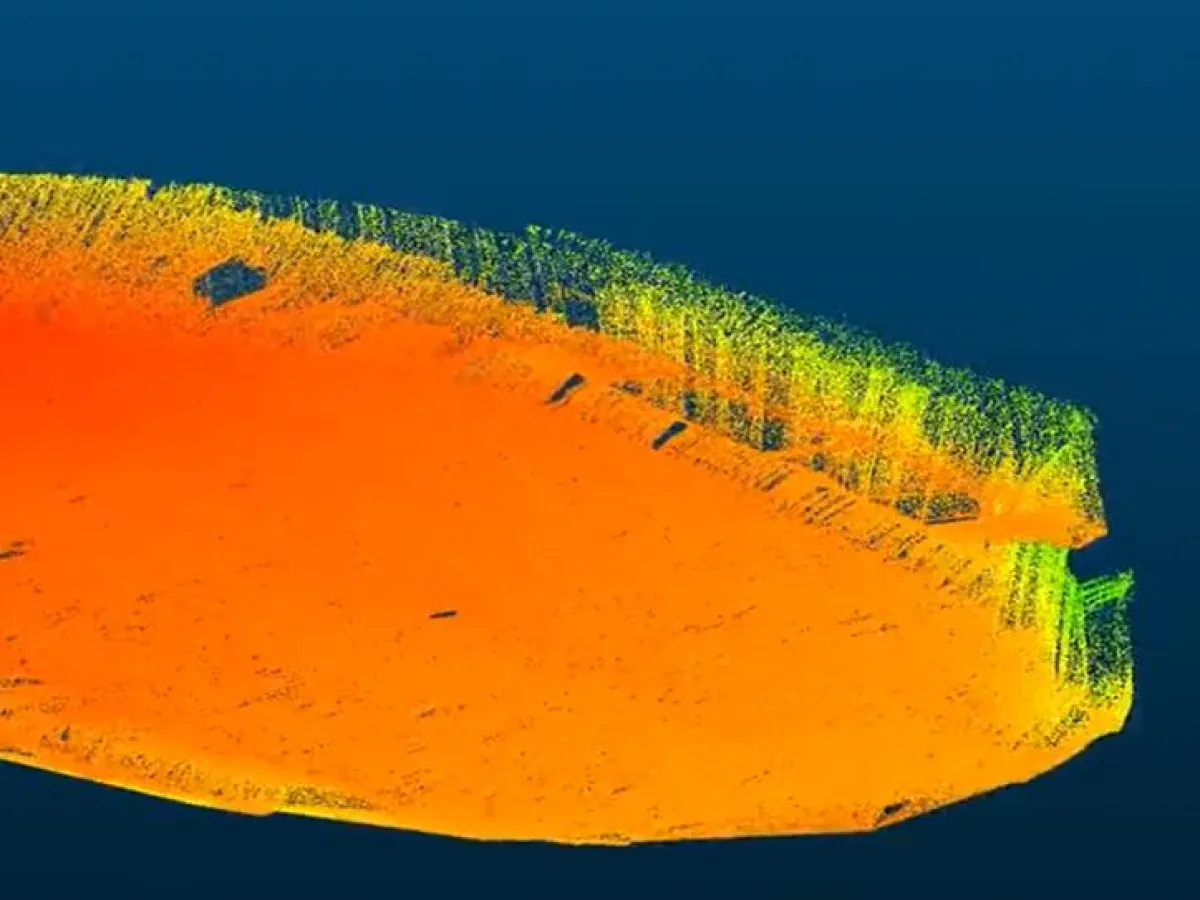
Built straight from raw acoustic data at the flat keel and bilge keel.
RON-OS turns any AUV or ROV into an autonomous hull-inspection system, at berth


Complete hull coverage at berth, without drydock.


Quantify biofouling to manage fuel consumption and emissions.


Collision and grounding damage assessment.


Screening for suspicious attachments below the waterline.
One autonomous workflow, end to end. Full-hull coverage at berth, no drydock, no downtime.

Define survey scope, route, and sensor configuration for the asset.
Launch on site with a 1–2 person crew, operational within minutes.
RON follows the structure at zero visibility, no divers, no downtime.
Cloud reconstruction produces a cm-accurate 3D model with ML-flagged anomalies.
An interactive, shareable 3D dataset for the operator.
Export into asset management systems for year-over-year comparison.
Start with a baseline survey
Full-hull inspection at berth, quantifies biofouling and structural damage without drydock.