Offshore structures deteriorate unnoticed in deep, dark water. Inspection windows are short, weather-dependent, and expensive
From a real deep-water deployment to flagged anomalies
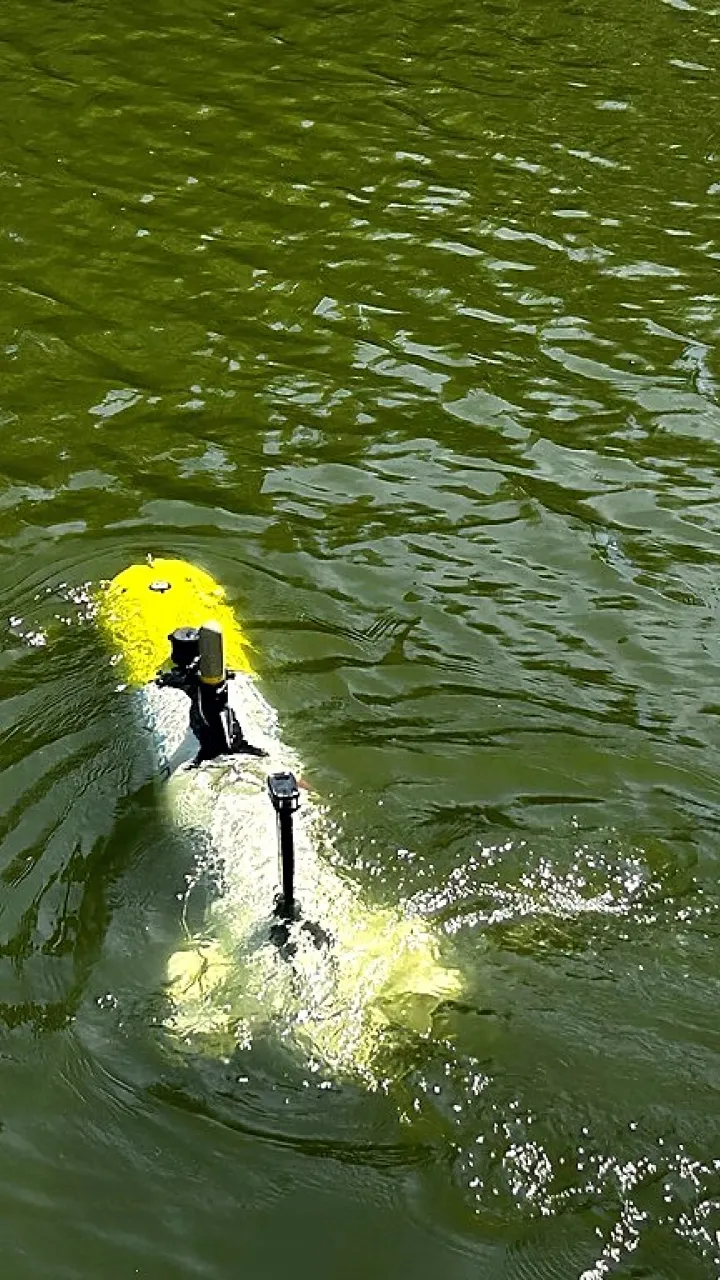
Real subdron mission at an offshore site. What the vehicle collects becomes a sonar sweep with anomalies automatically flagged for engineering review.
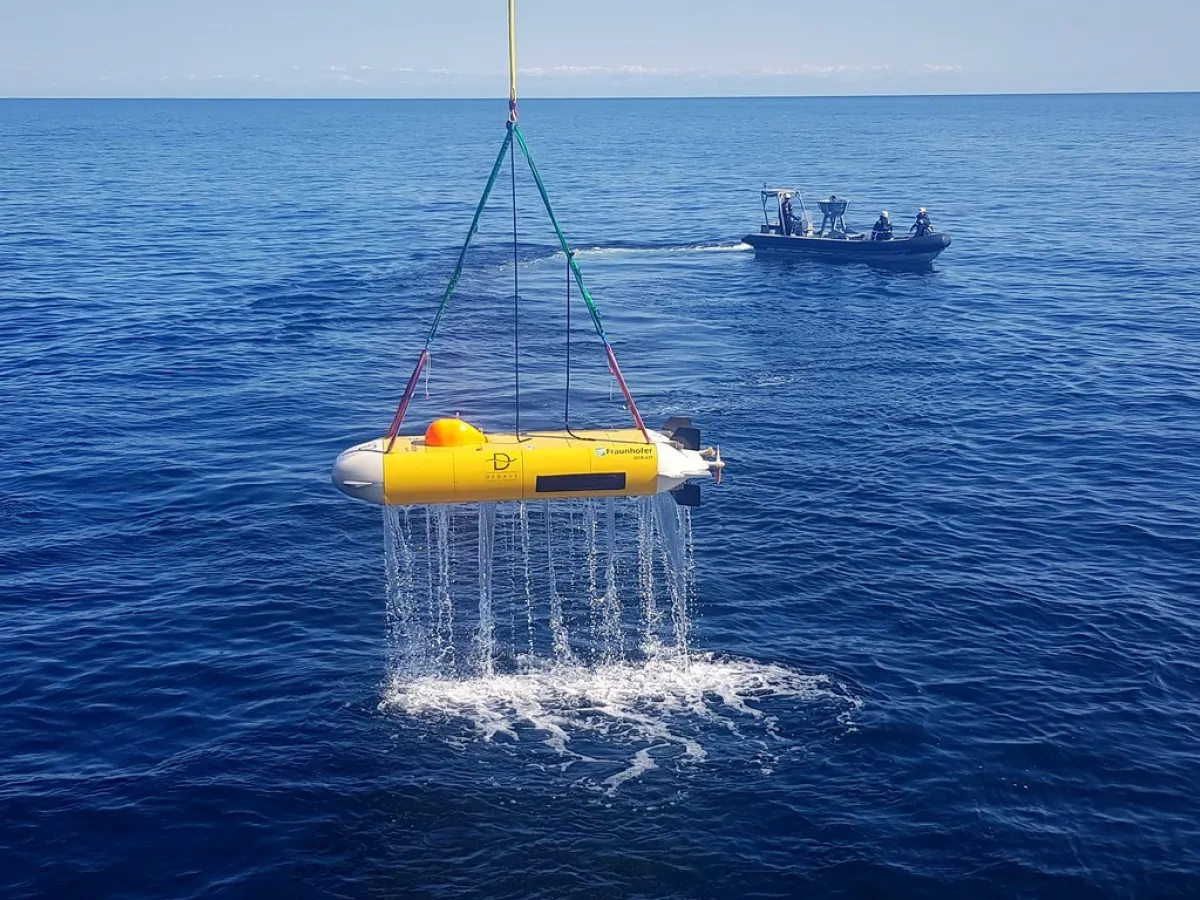
Launched from a small support vessel, no diver support required.

A continuous sonar sweep of the structure, with objects of interest located precisely.
RON-OS turns any AUV or ROV into a deep-water inspection system for foundations and offshore-wind cables


Autonomous structural inspection to 200 m, with deep-sea capability in development.


Measurable 3D models with ML-flagged anomalies.


Complete coverage in a single pass, regardless of visibility.


Integration into asset integrity programs.
One autonomous workflow, end to end. Structural inspection to 200 m today, in a single pass.

Define survey scope, route, and sensor configuration for the asset.
Launch on site with a 1–2 person crew, operational within minutes.
RON follows the structure at zero visibility, no divers, no downtime.
Cloud reconstruction produces a cm-accurate 3D model with ML-flagged anomalies.
An interactive, shareable 3D dataset for the operator.
Export into asset management systems for year-over-year comparison.
Start with a baseline survey
Autonomous structural surveying of subsea foundations and energy installations at depth.